Syntari: Mapping the work robots need to learn
I see a future in which robot manufacturers need libraries of training programs to help their machines become useful in specific roles. Syntari began as a way to explore what that library might need to contain: how to organize it, what should inform the training, and which capabilities different robots have in common.
Today, Syntari is an R&D project run, managed, and operated by AI agents. Its focus is research into manufacturers, capabilities, and archetypes that could provide a foundation for future robotic programming and training.
An Arc starts with the work
We call an archetype an Arc. The idea is similar to a human persona: define relevant attributes, then use them to give a particular role a clear identity within a broader category.
Manufacturing is one example of a category. Within it, a robot involved in car manufacturing and one carrying out light textile assembly would belong to different archetypes. They share an industry category, but the work they need to do is different.
That distinction is central to the research. The category provides the broad context; the archetype focuses on a more specific function. We want to understand how those layers fit together and what common variables could support a useful training program.
Use agents to keep the research moving
Part of that work involves understanding which robots are in commercial development and what their manufacturers say they can do. We have an agent that continuously searches the internet for updates on manufacturers and capabilities.
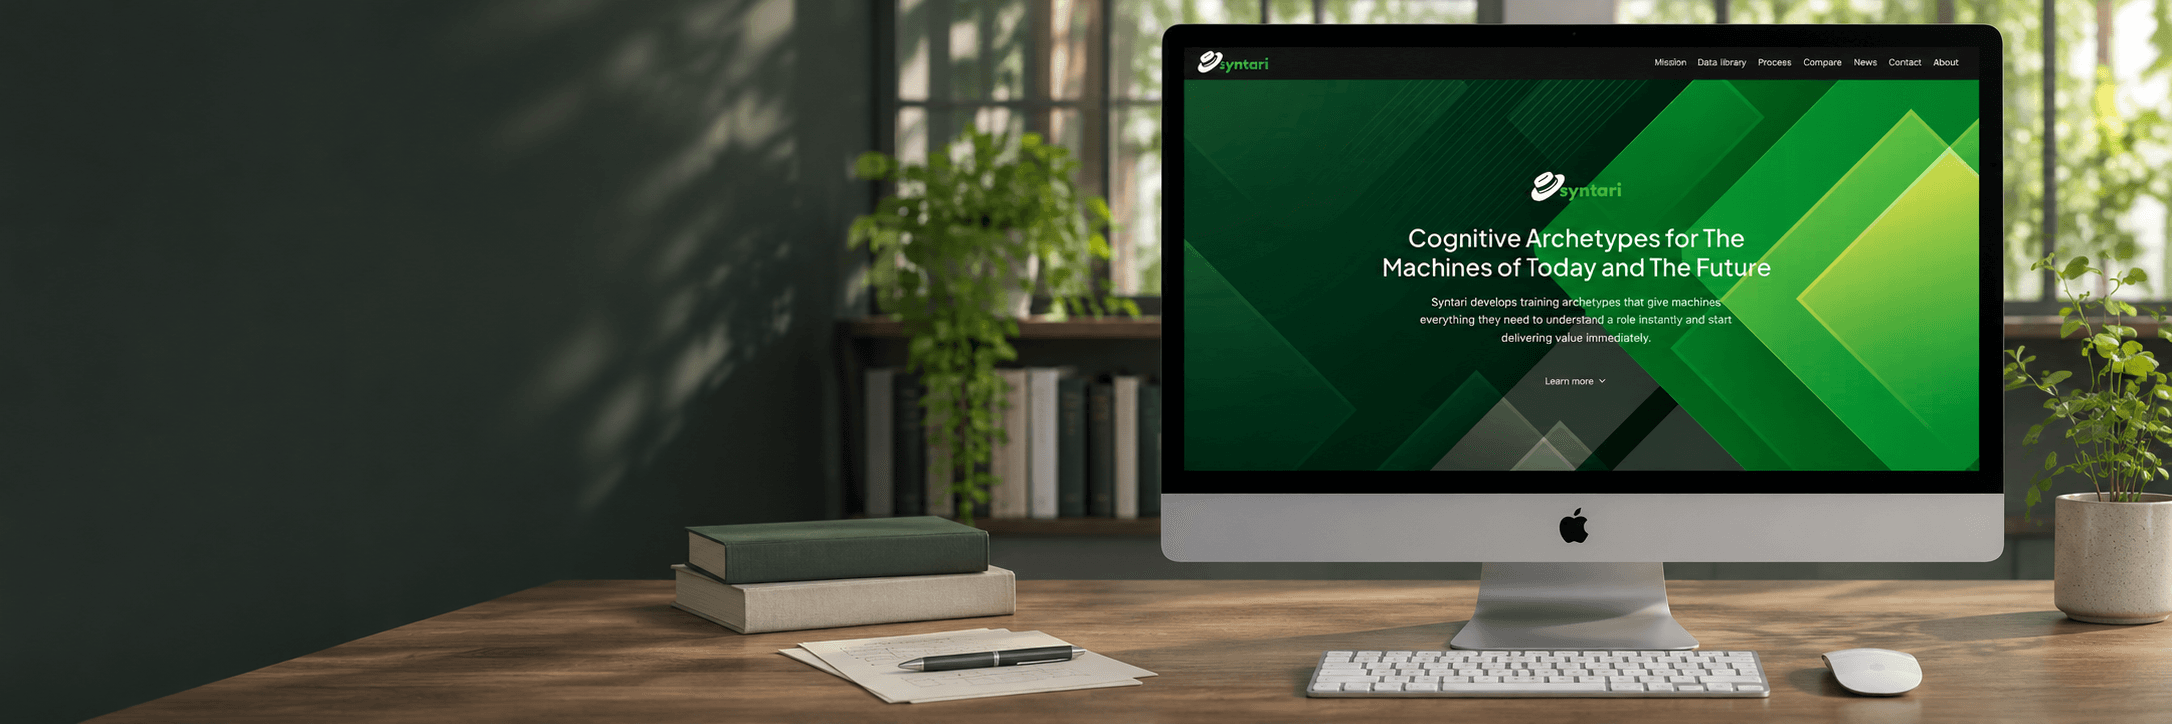
The Syntari website presents that research through archetype categories, a manufacturer directory, comparison views, news and updates, and a data library. These views bring different parts of the investigation into one place.
The public website is live as a place to share the project information and ongoing research. Its categories and research help us explore how a future programming and training platform might be structured.
From archetypes to training packages
The longer-term ambition is to develop precisely tuned programming that helps compatible robots become effective in their intended roles out of the box. Arcs would form part of the foundation for that work.
We see two possible ways to offer future training packages: customized versions for robot manufacturers, or packages sold directly to consumers to load onto compatible robots. Those are directions we are considering as the research develops.
At this stage, the work remains research. Physical-robot MVP development and commercial training packages are future steps.
The next phase needs hardware
We plan to seek funding to acquire a few leading robot models. That would allow us to begin developing MVPs and use that work to develop and grow the platform.
The immediate purpose of Syntari is to investigate the structure behind that ambition: the manufacturers and capabilities to understand, the categories to organize, and the roles an Arc would describe. Funding, hardware acquisition, and MVP development would take the project into its next phase.